Robotic Gripping Feedback — Fragile Assembly Cells
Tactile fingertip arrays give each gripper closed-loop force control for PCB and connector handling, cutting crush defects across mixed part families.
System Overview
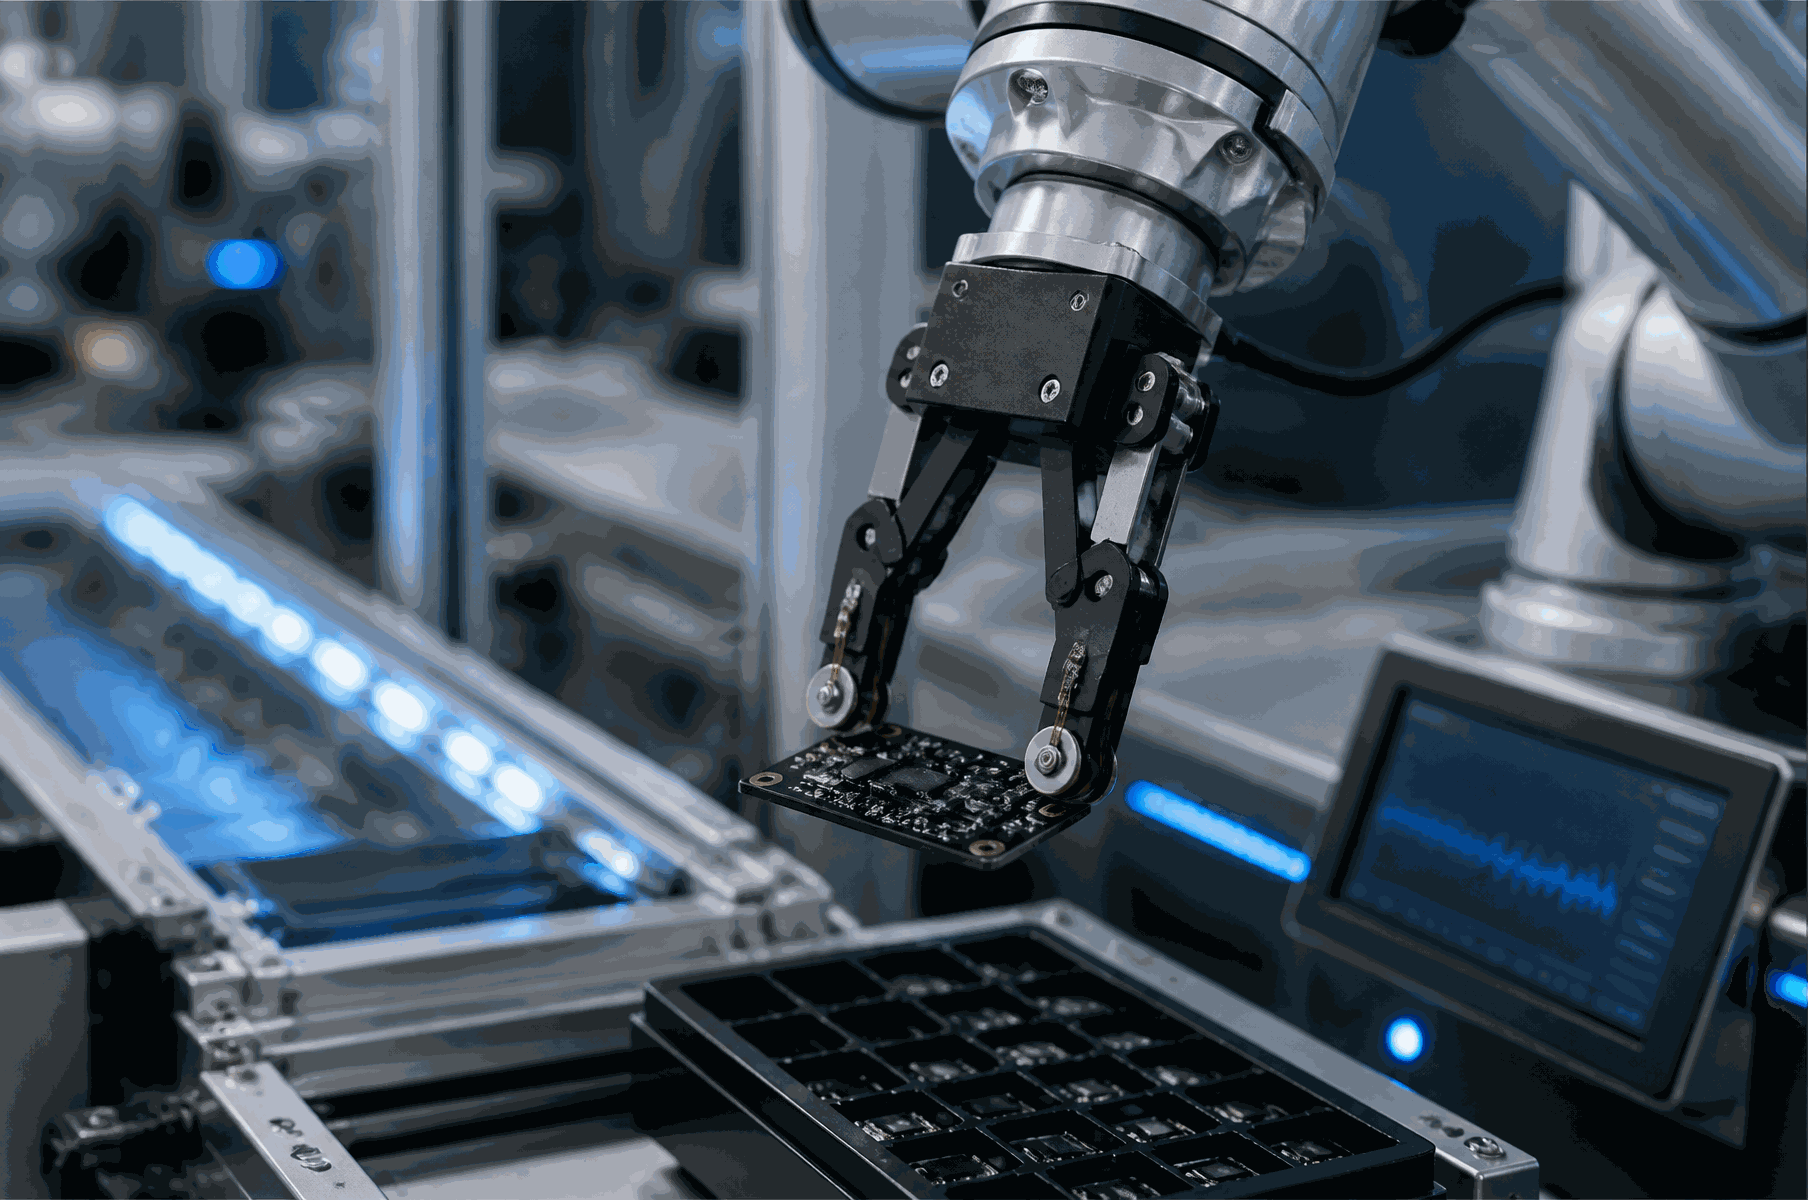
A tactile fingertip sensing system for parallel robot grippers used in electronics assembly. Multi-node FSR arrays on both fingertips give the robot real force feedback for fragile and mixed parts, replacing blind position-based grasping.
How It Works
During the closing stroke, the fingertip arrays report the growing contact force on each finger. The gripper controller stops closing once the configured force threshold is reached, then keeps monitoring the signal: a sudden shear change indicates slip, so the grip is re-tightened automatically. Process results are reported over the robot IO or serial bus.
On-Site Deployment & Sensor Integration
Related Projects
Planning a similar deployment?
Share your target force range, sensing area and integration constraints with our engineers.